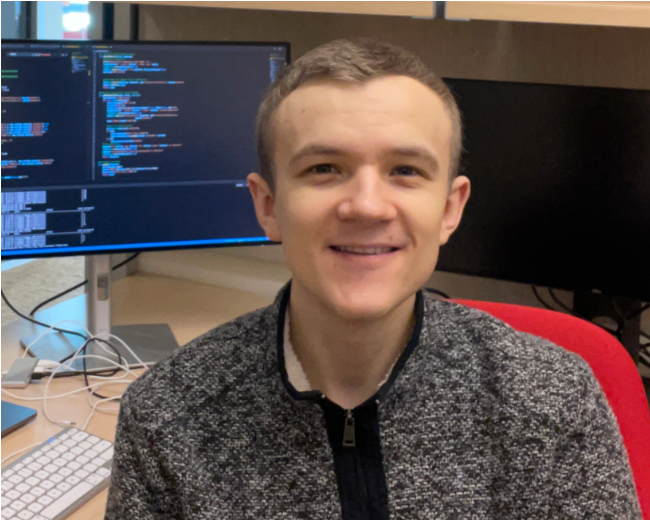
PhD Student at MIT
pschro@mit.edu
Philip Schroeder
I am a final-year PhD student at MIT in Electrical Engineering & Computer Science, advised by Dr. Jim Glass.
My work has focused on improving the reasoning and reward prediction capabilities of large language models (LLMs) and vision-language models (VLMs) in challenging embodied settings.
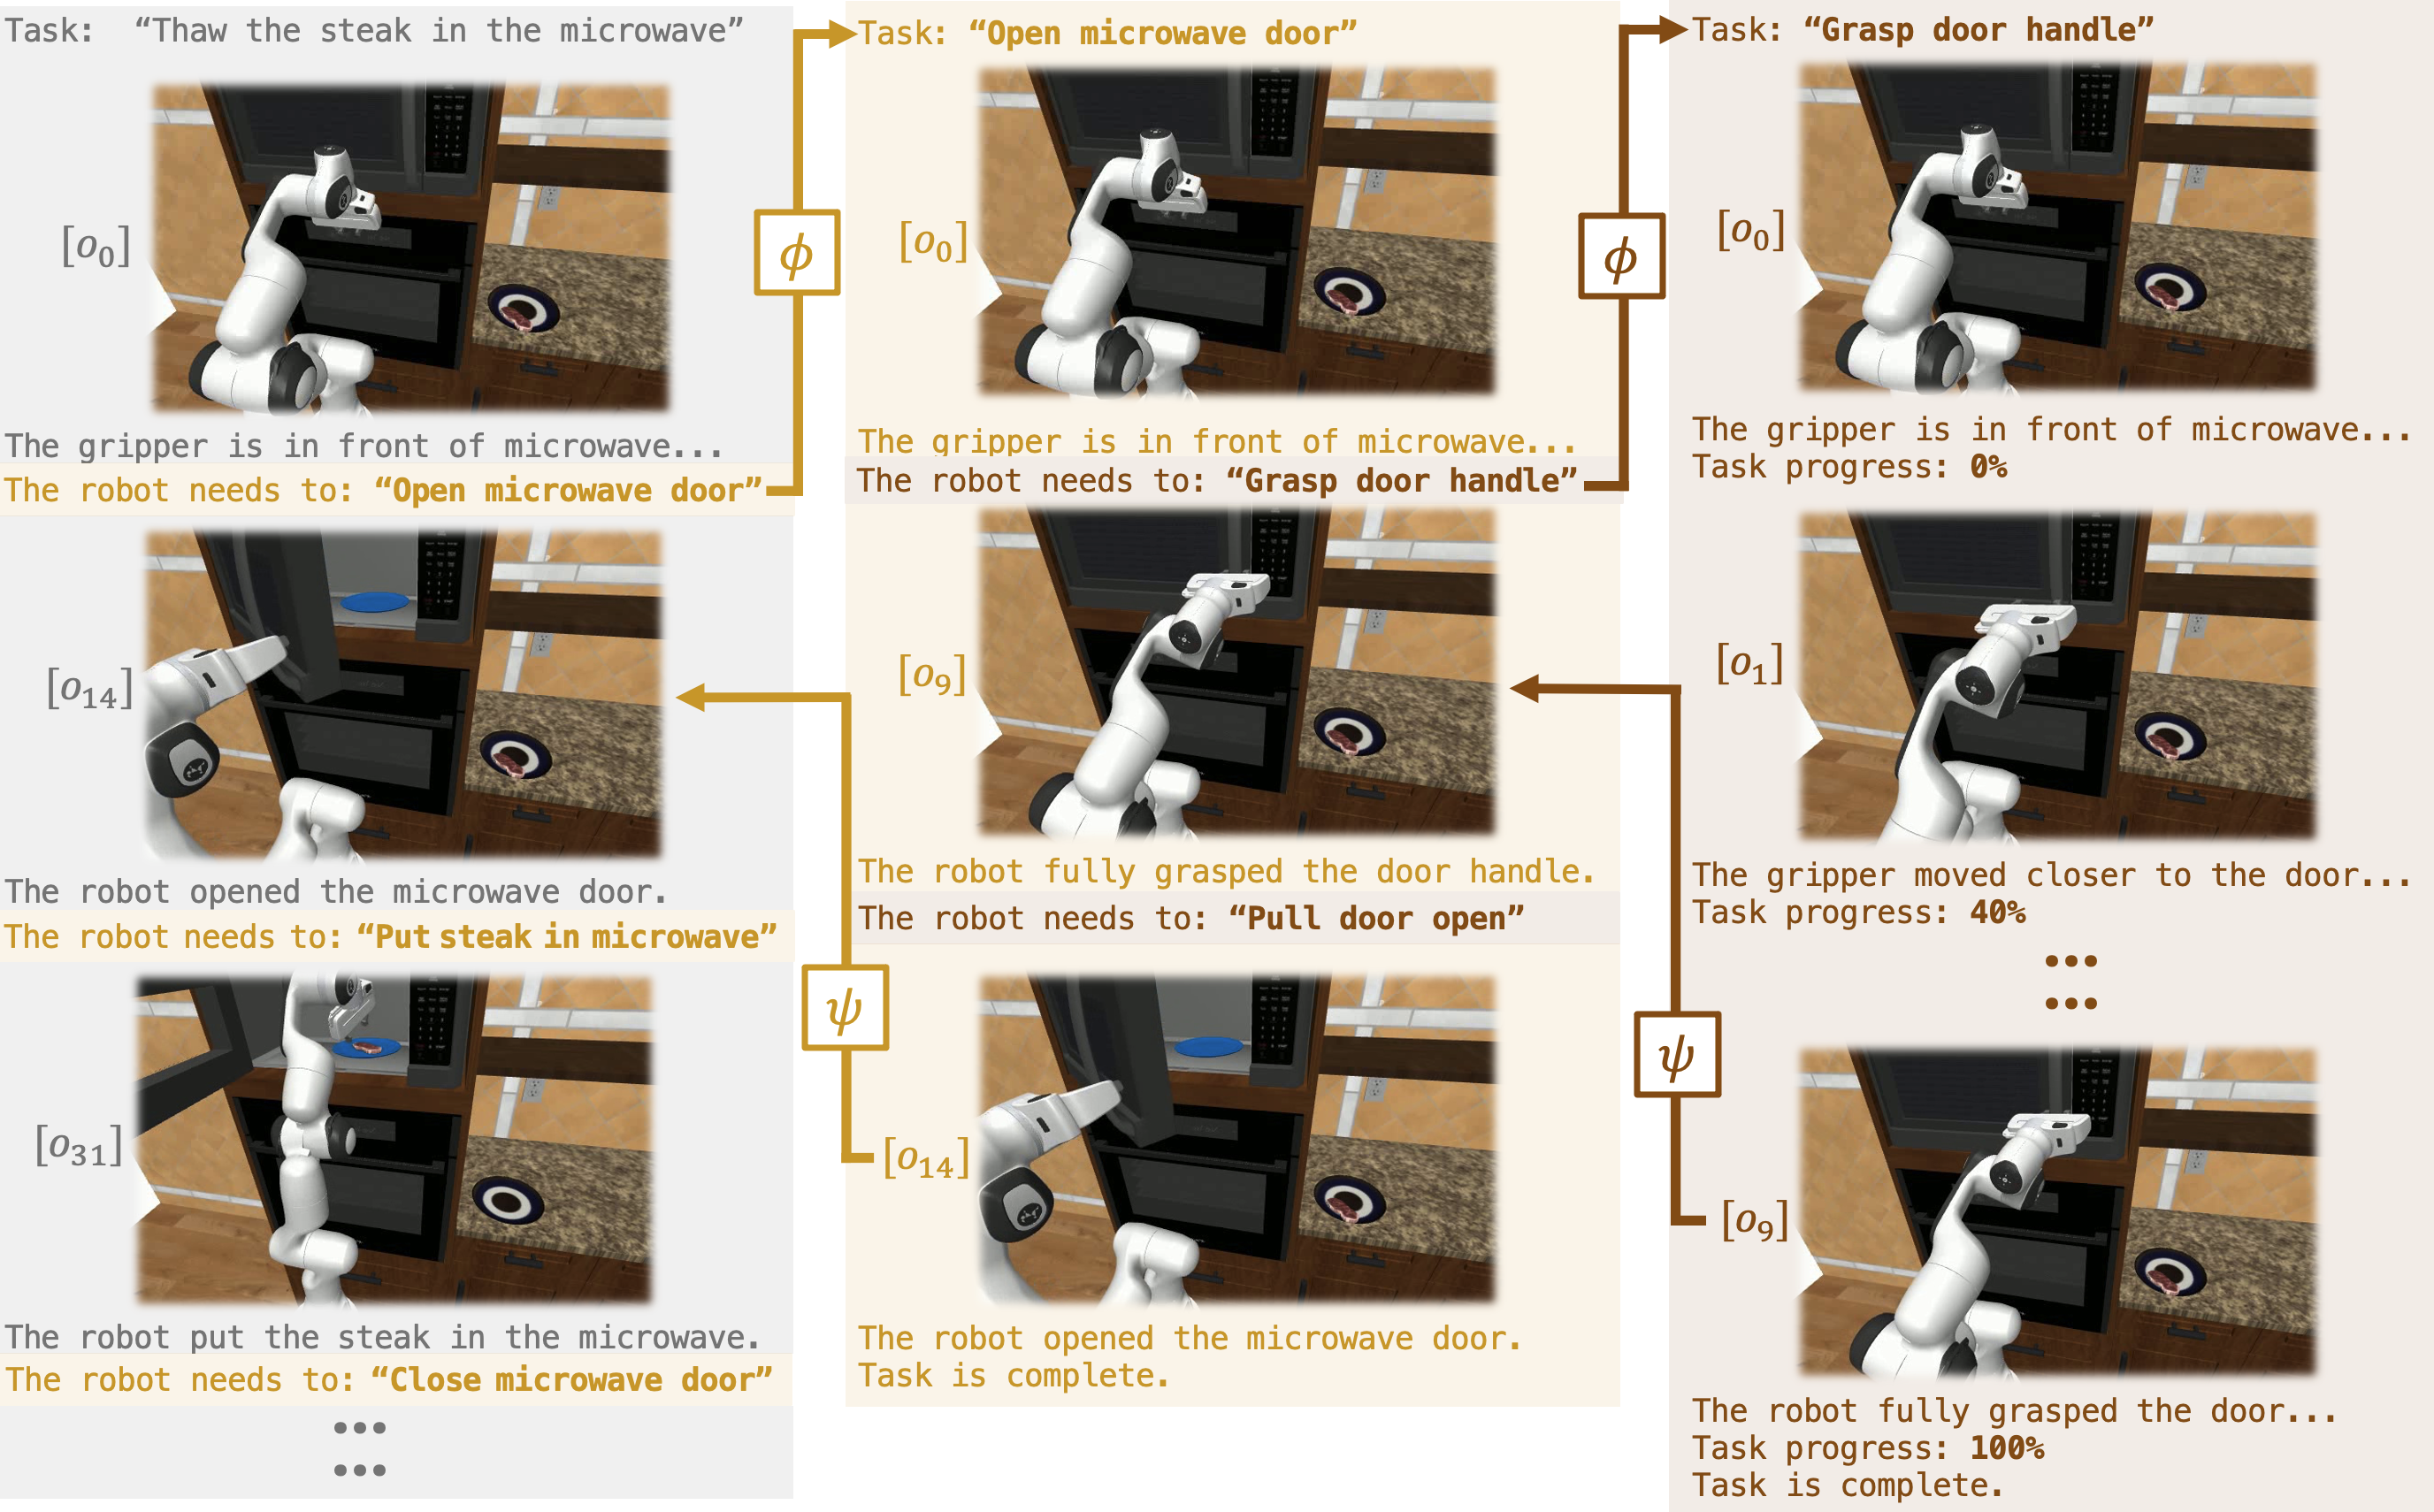
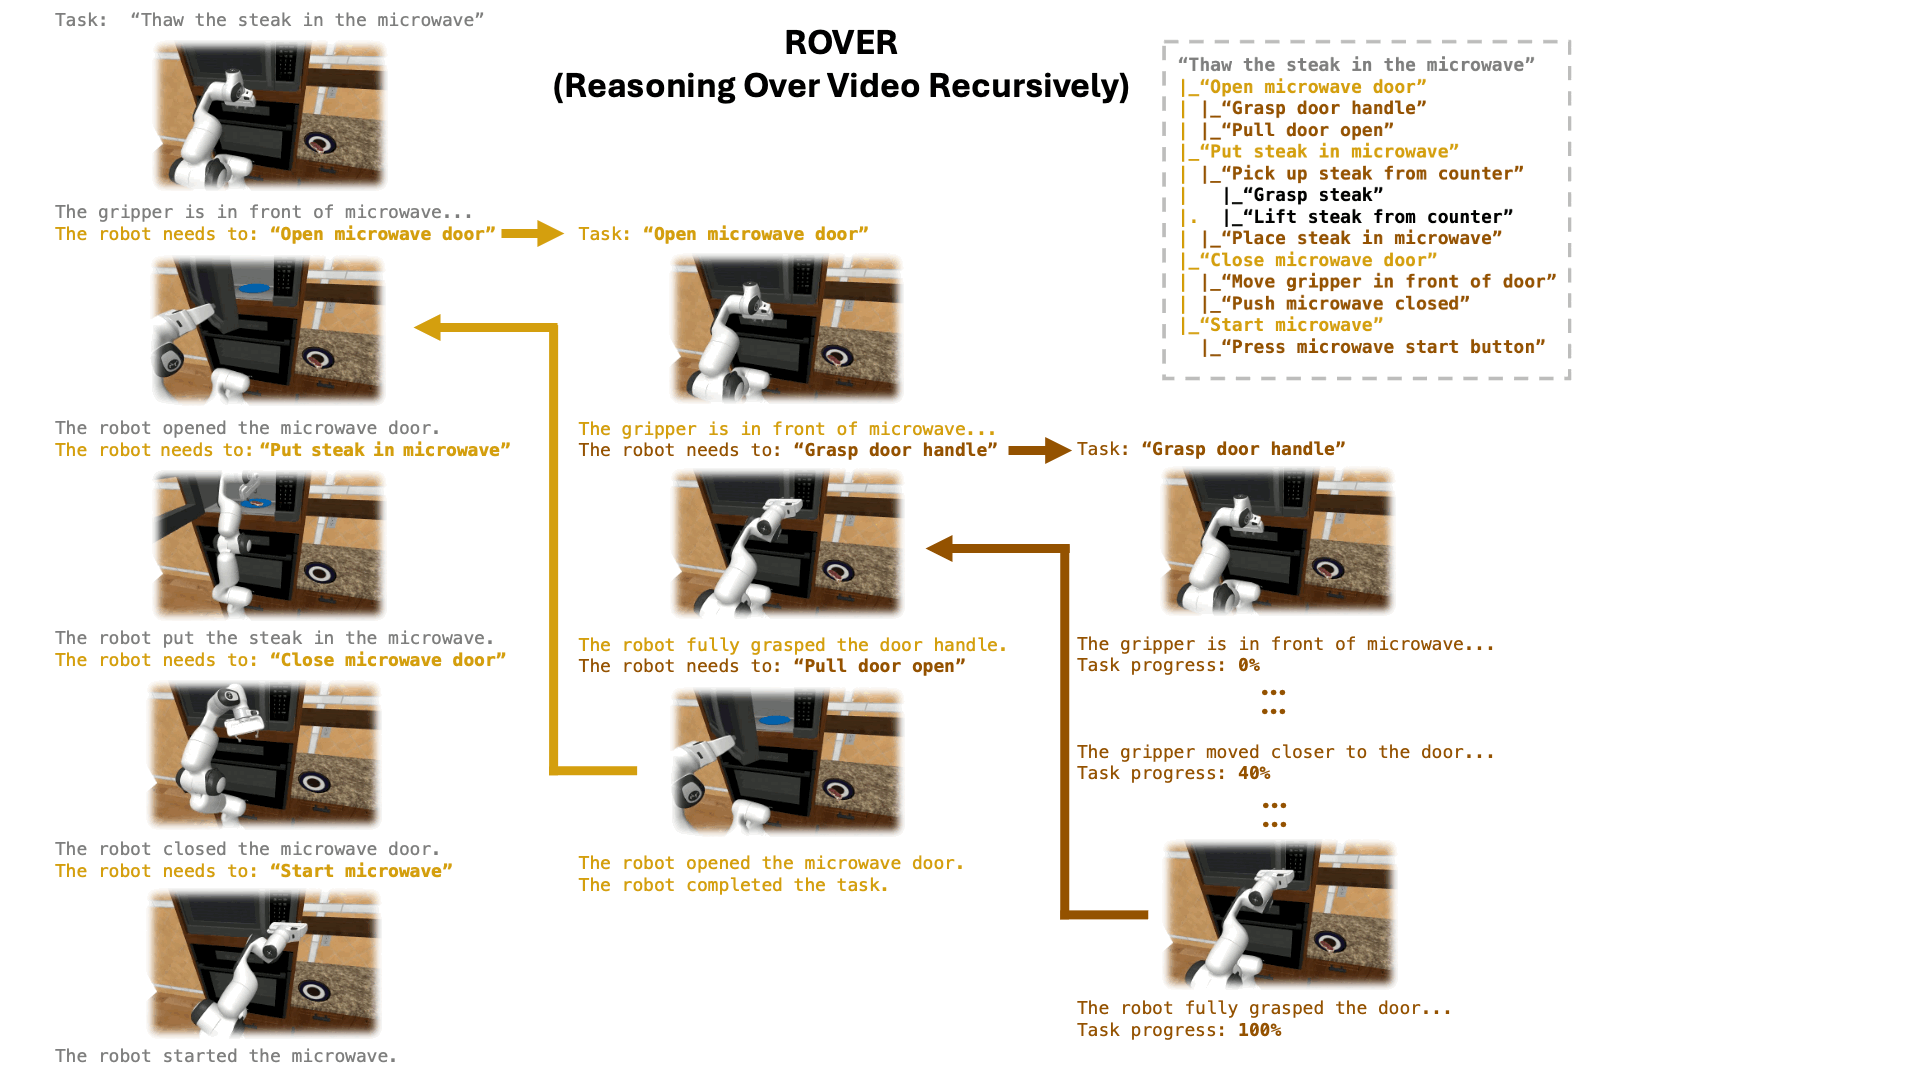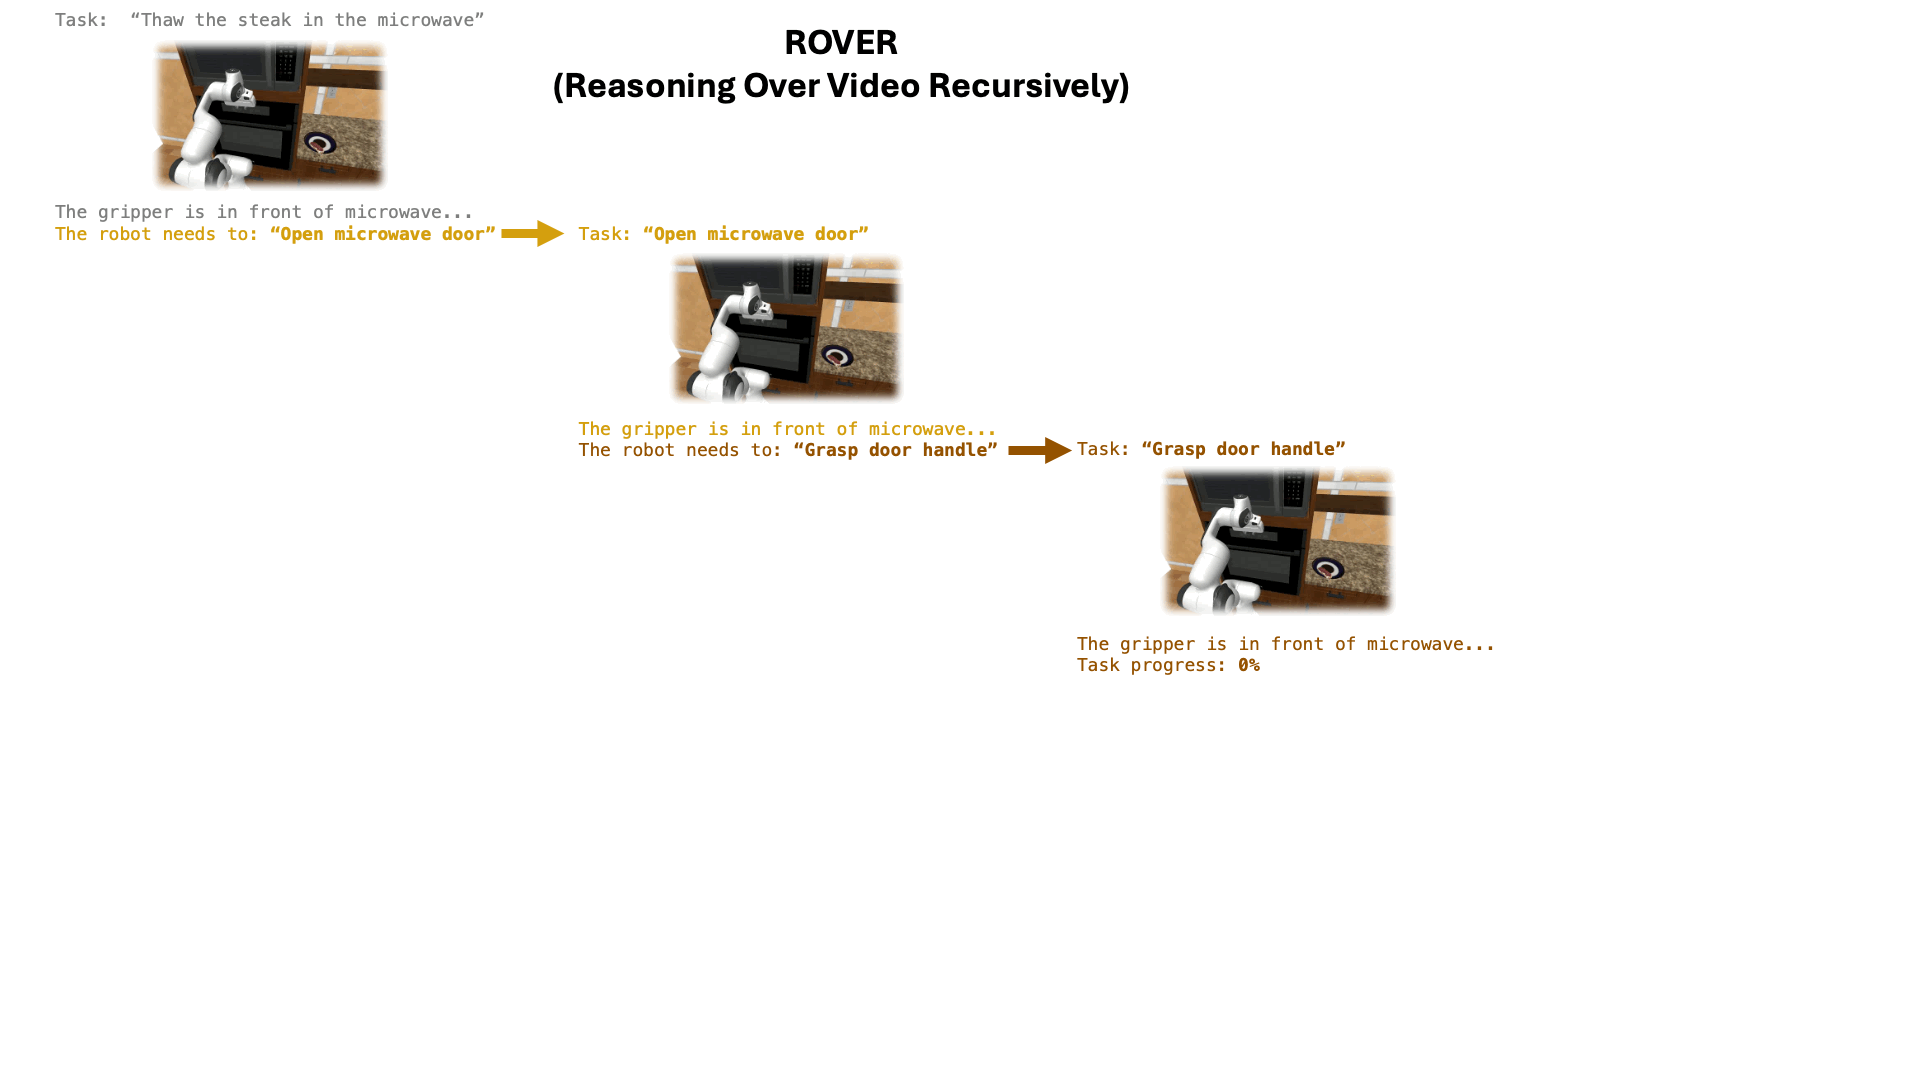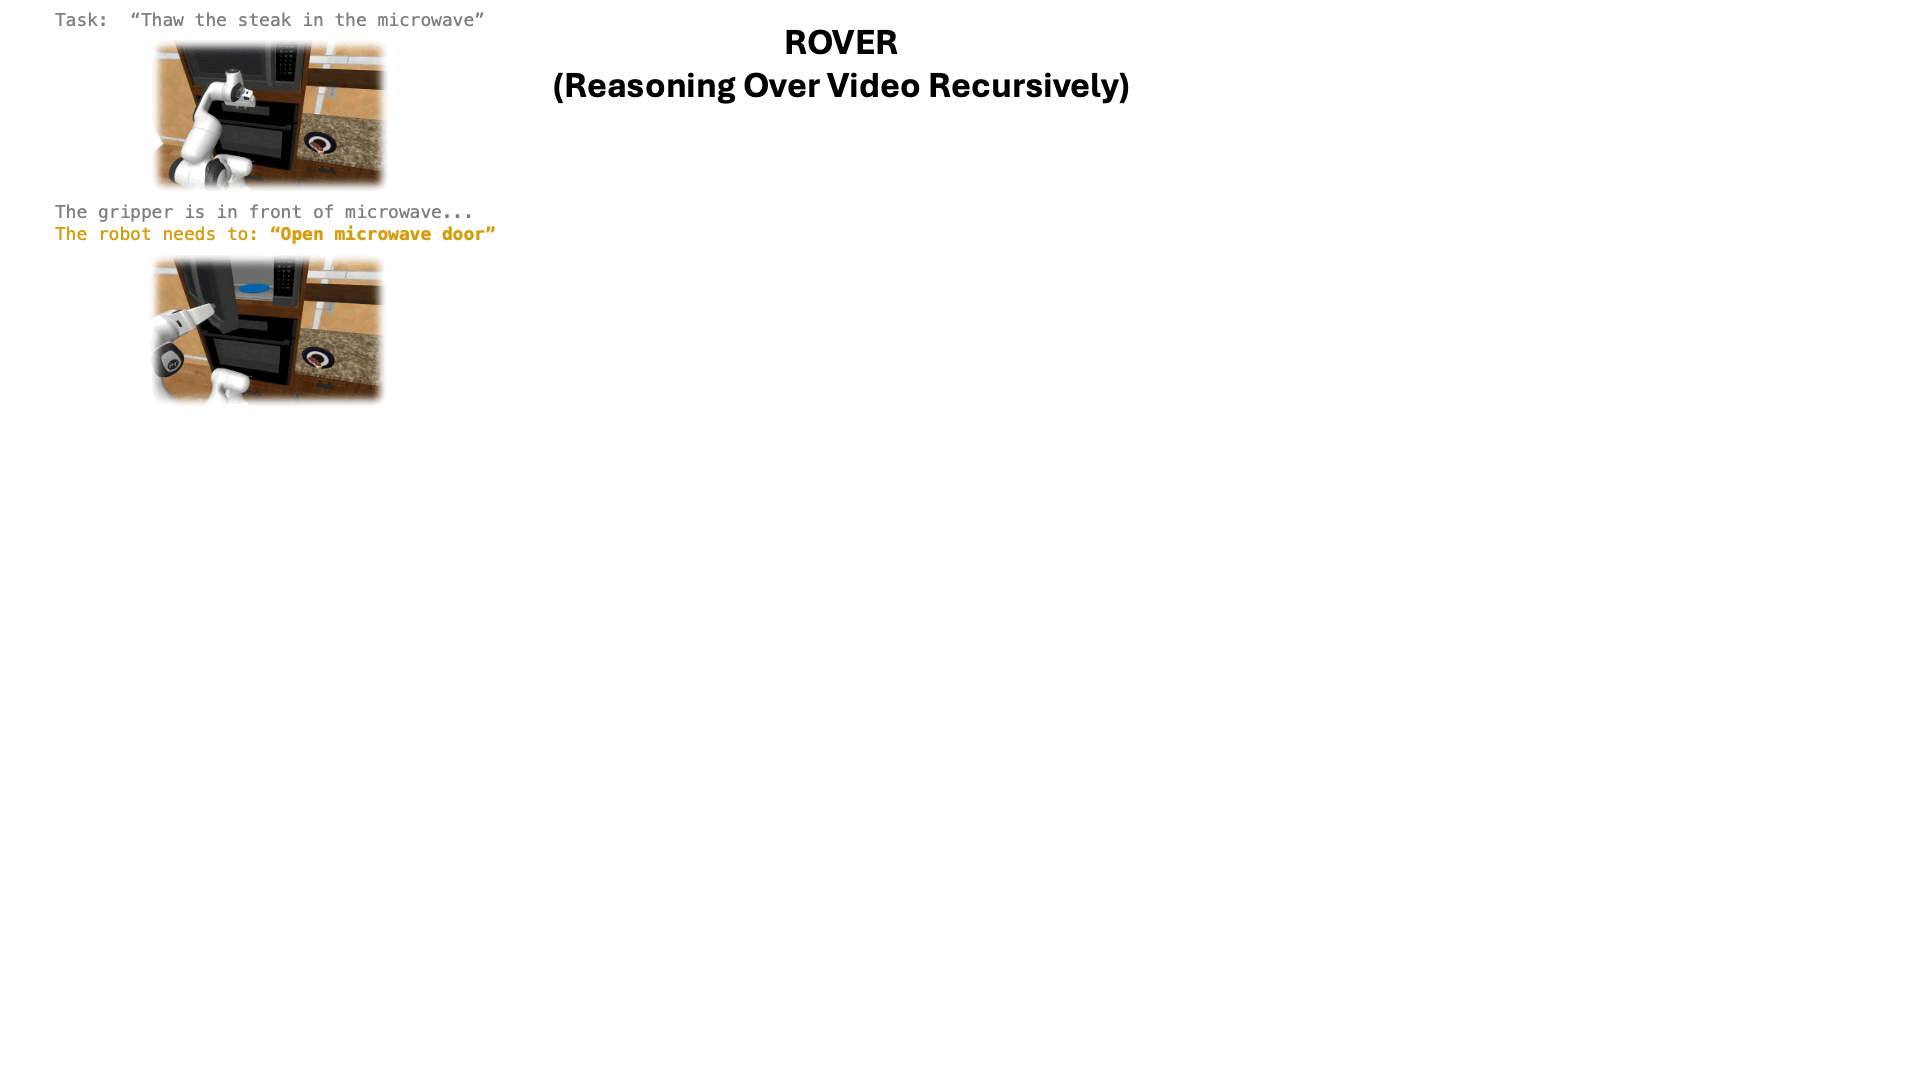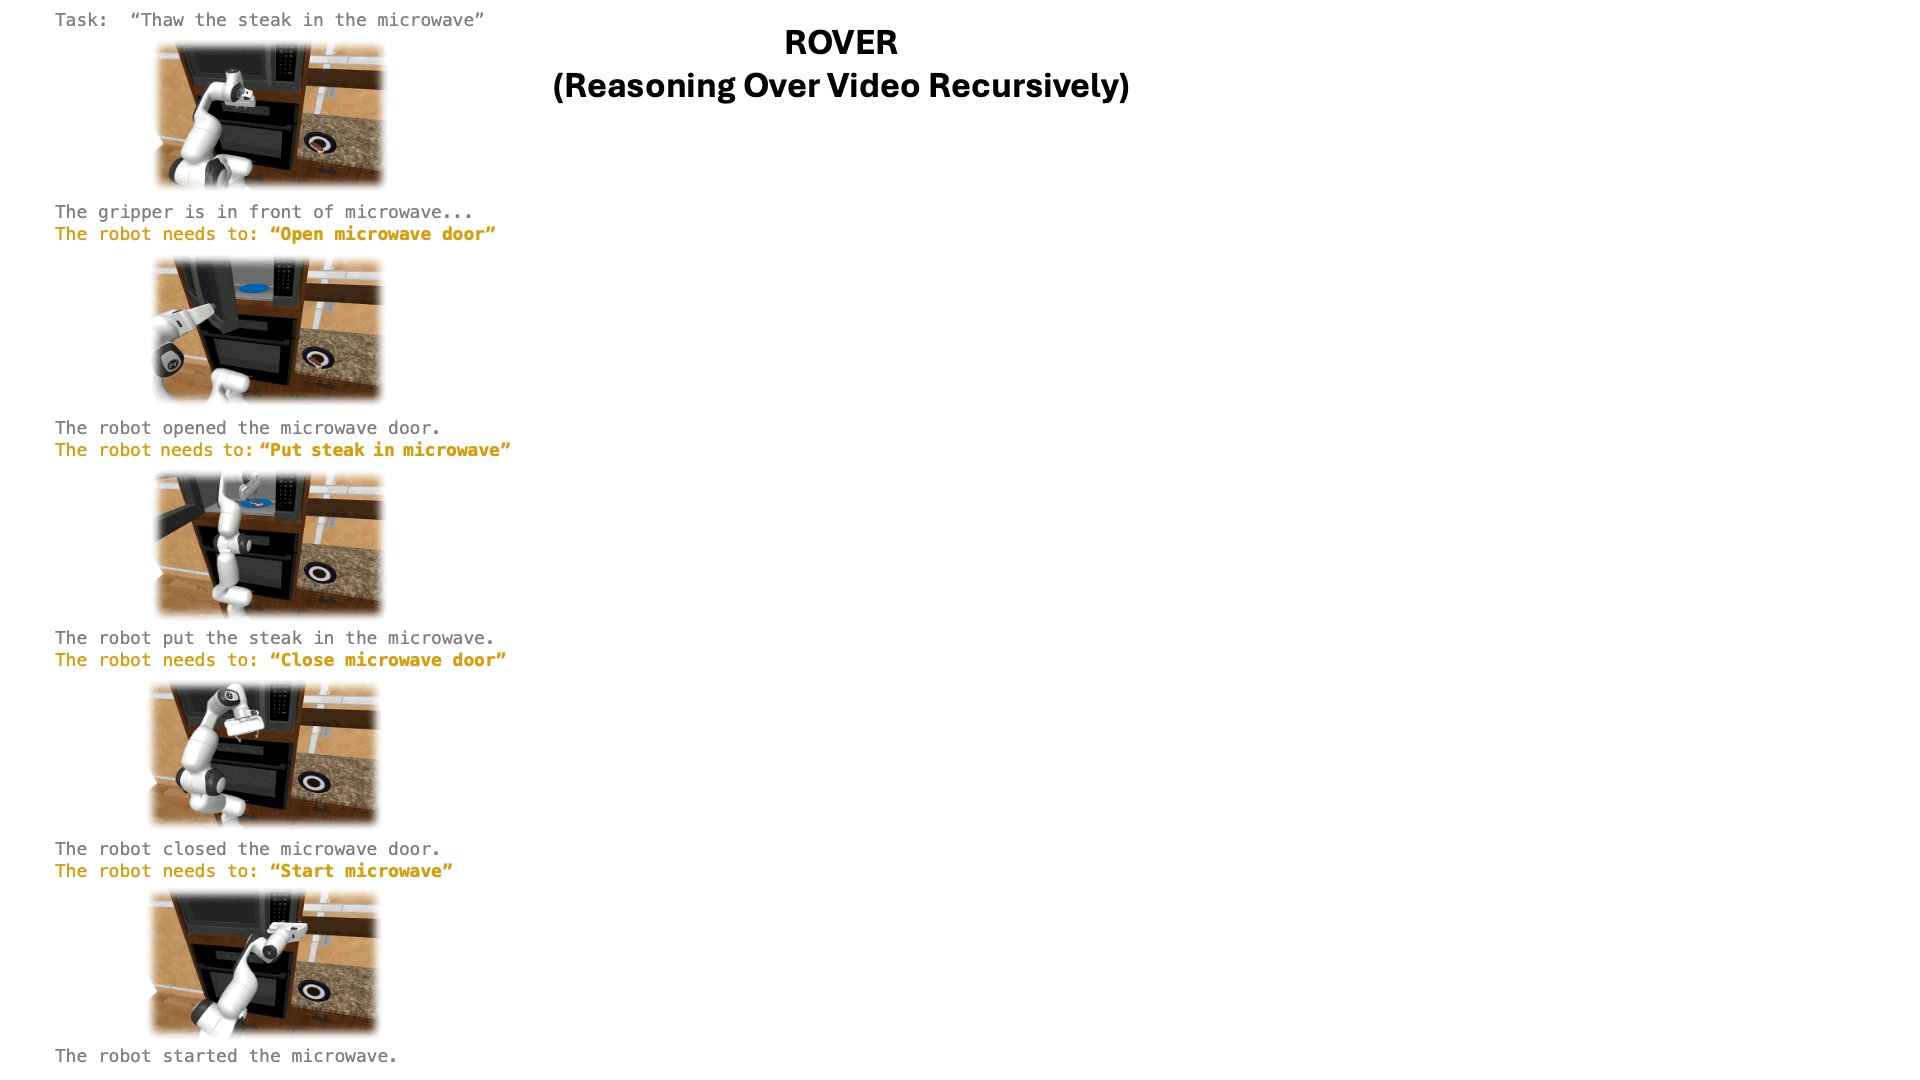
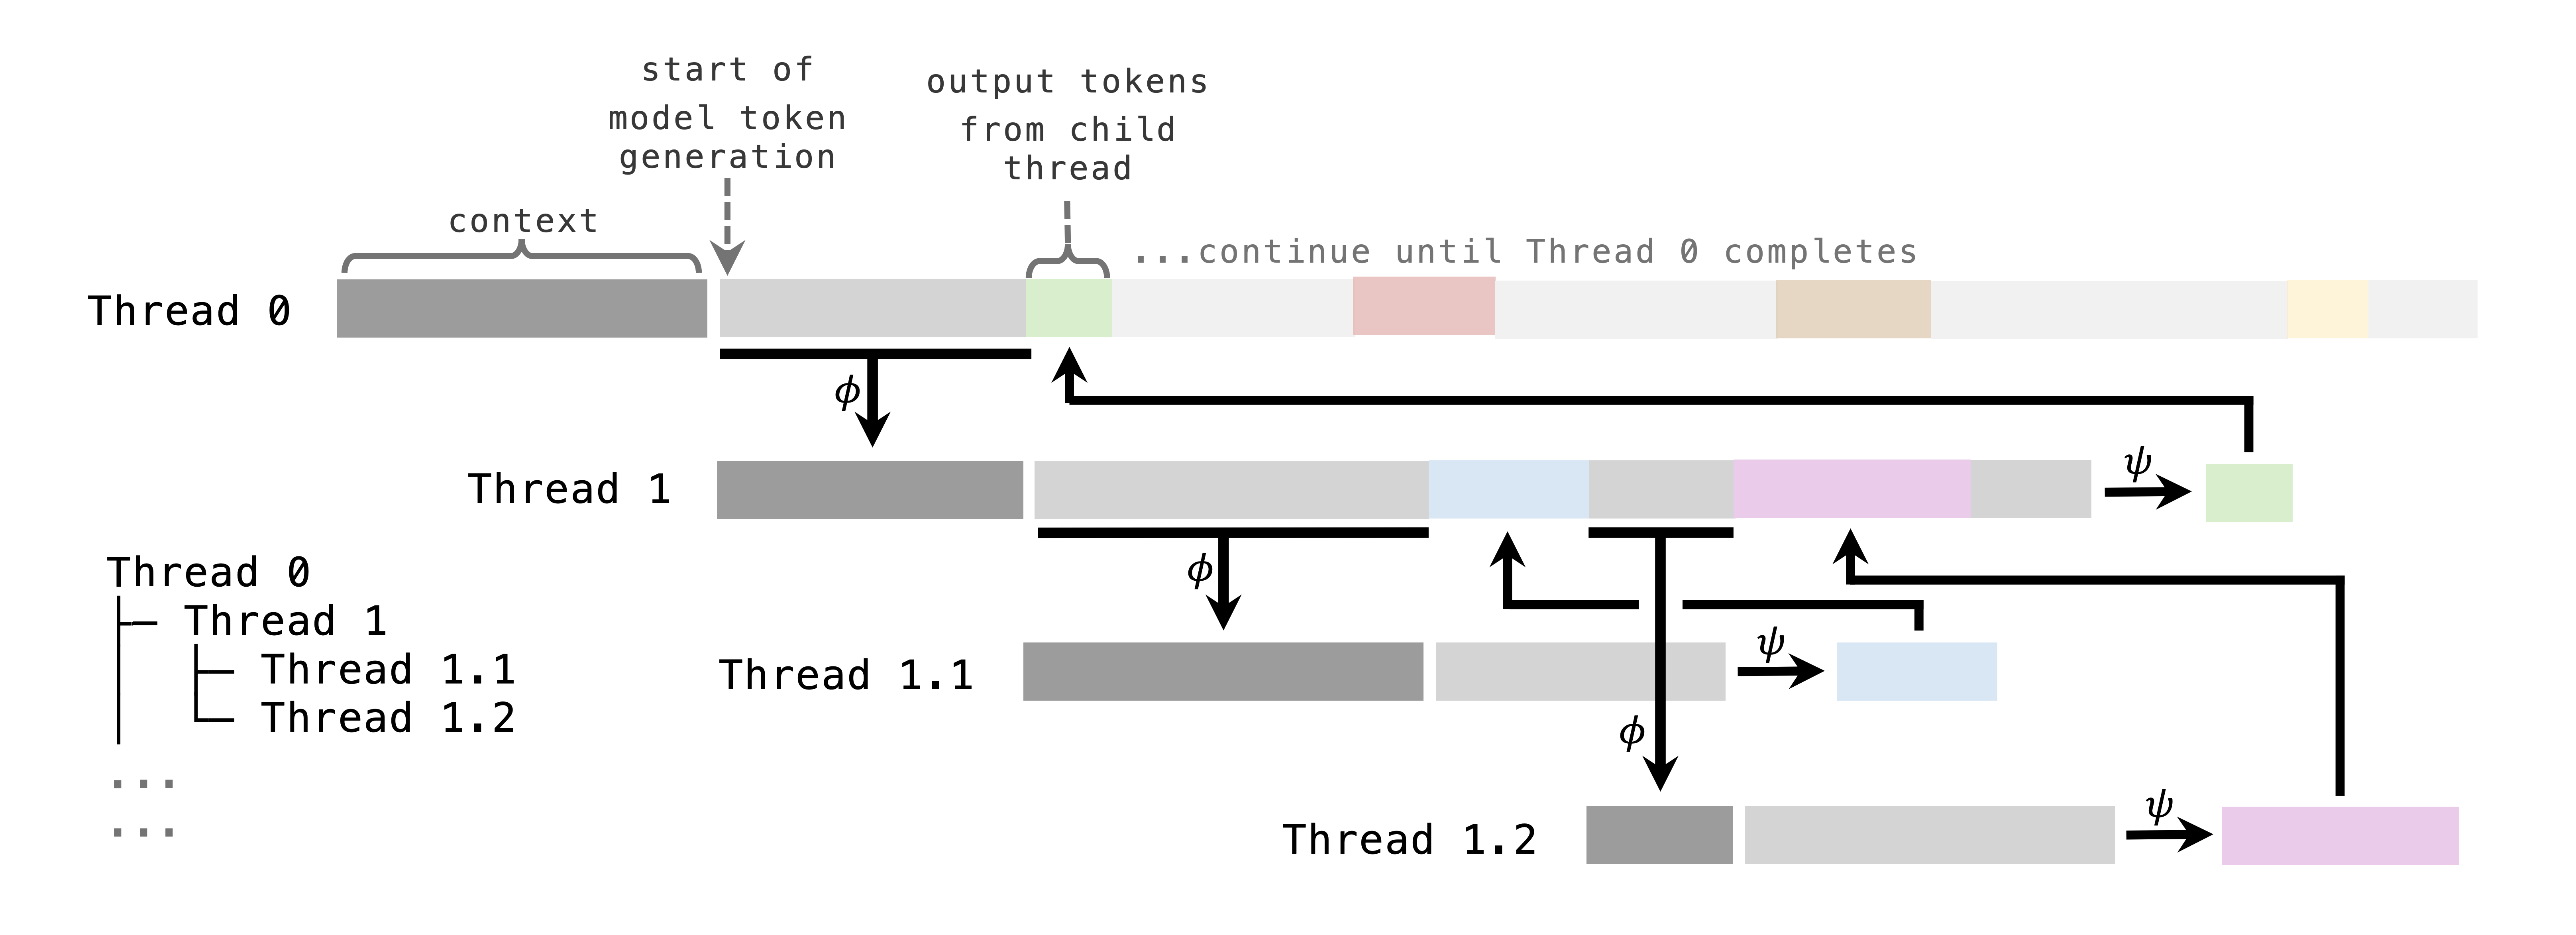
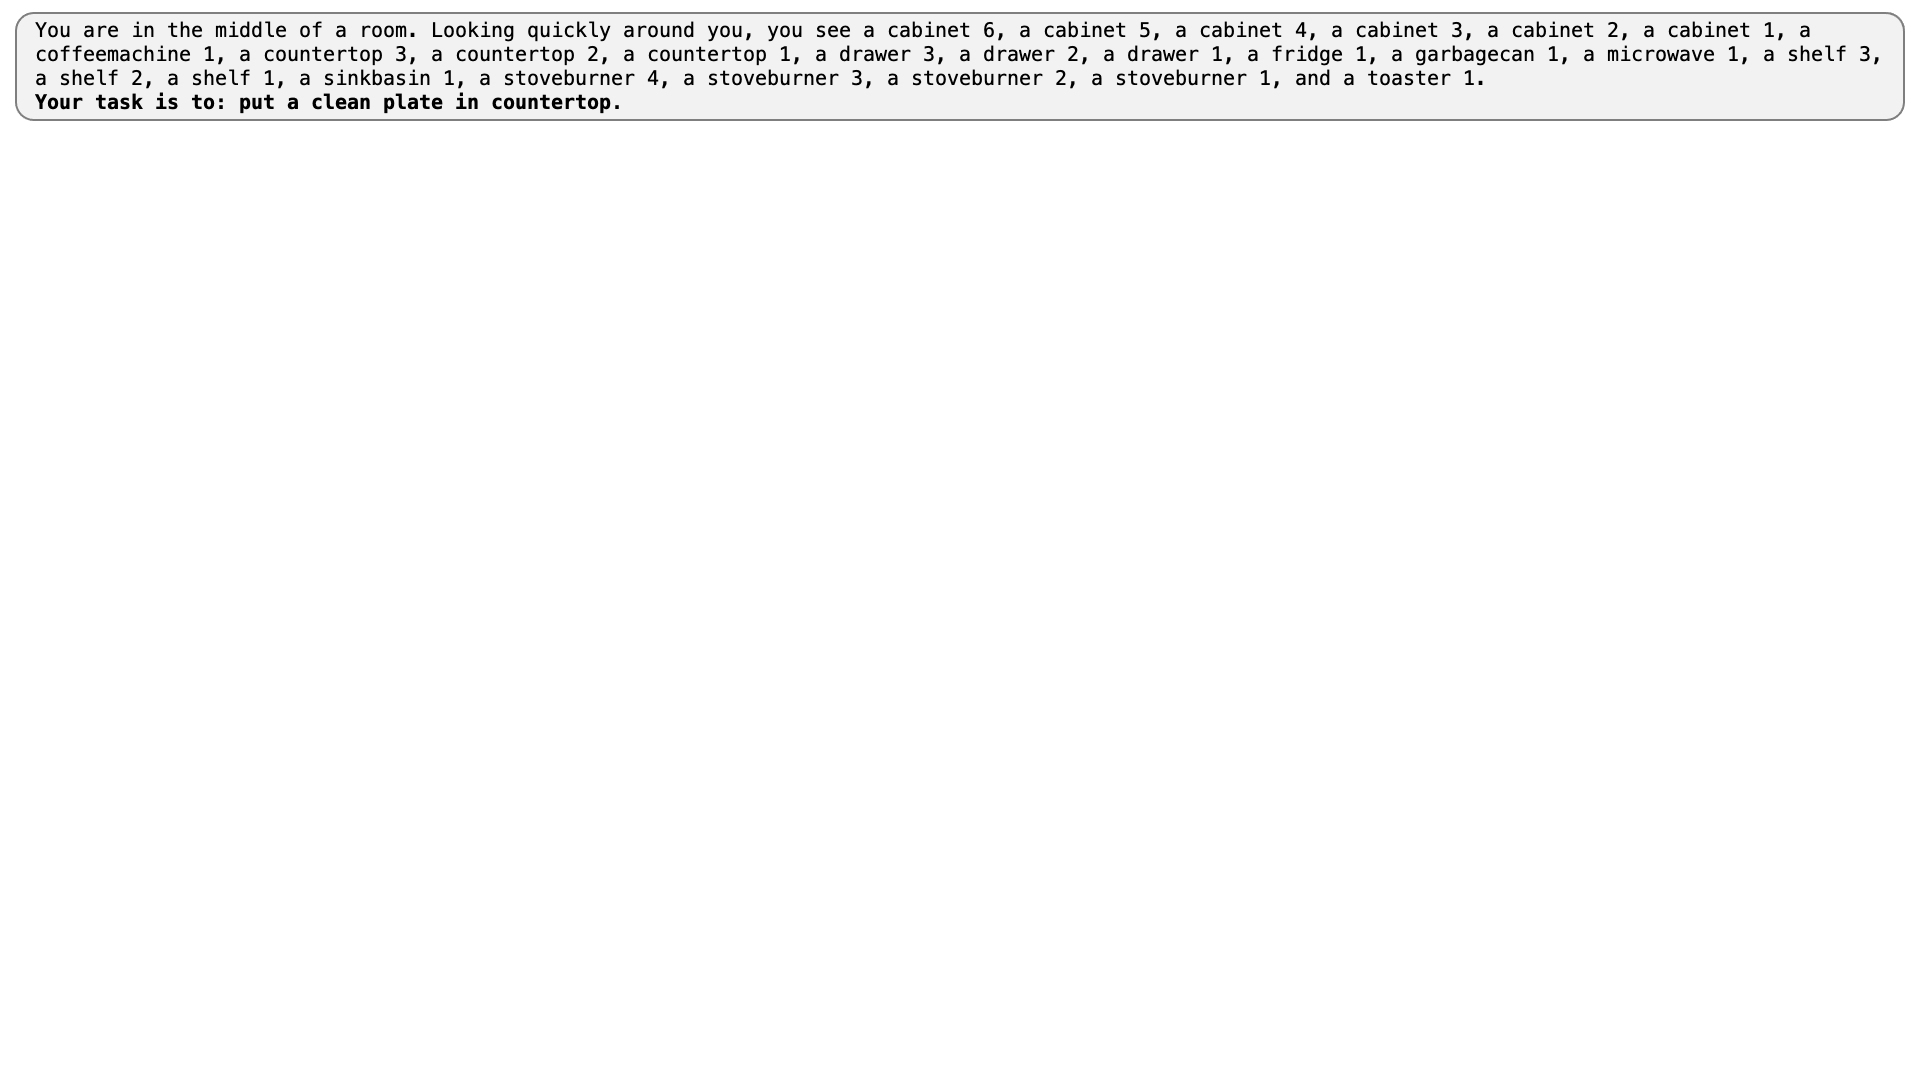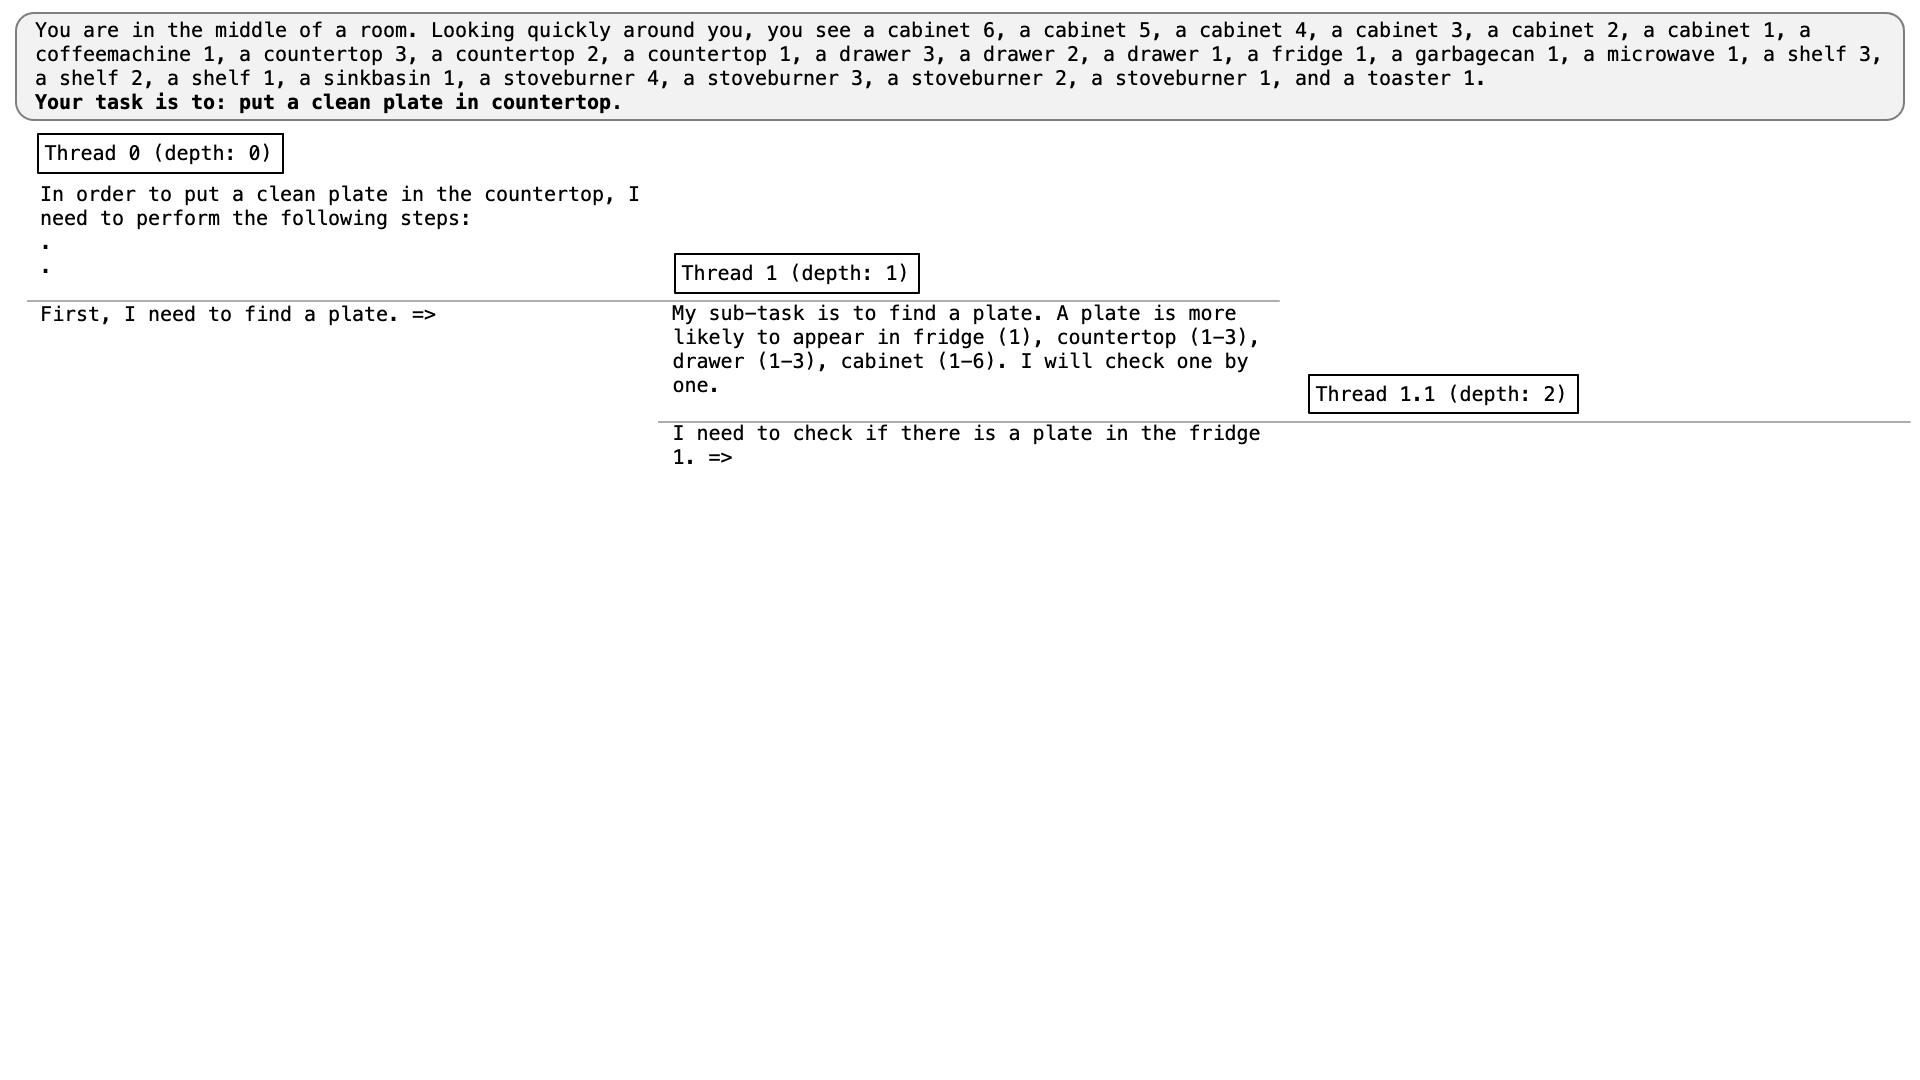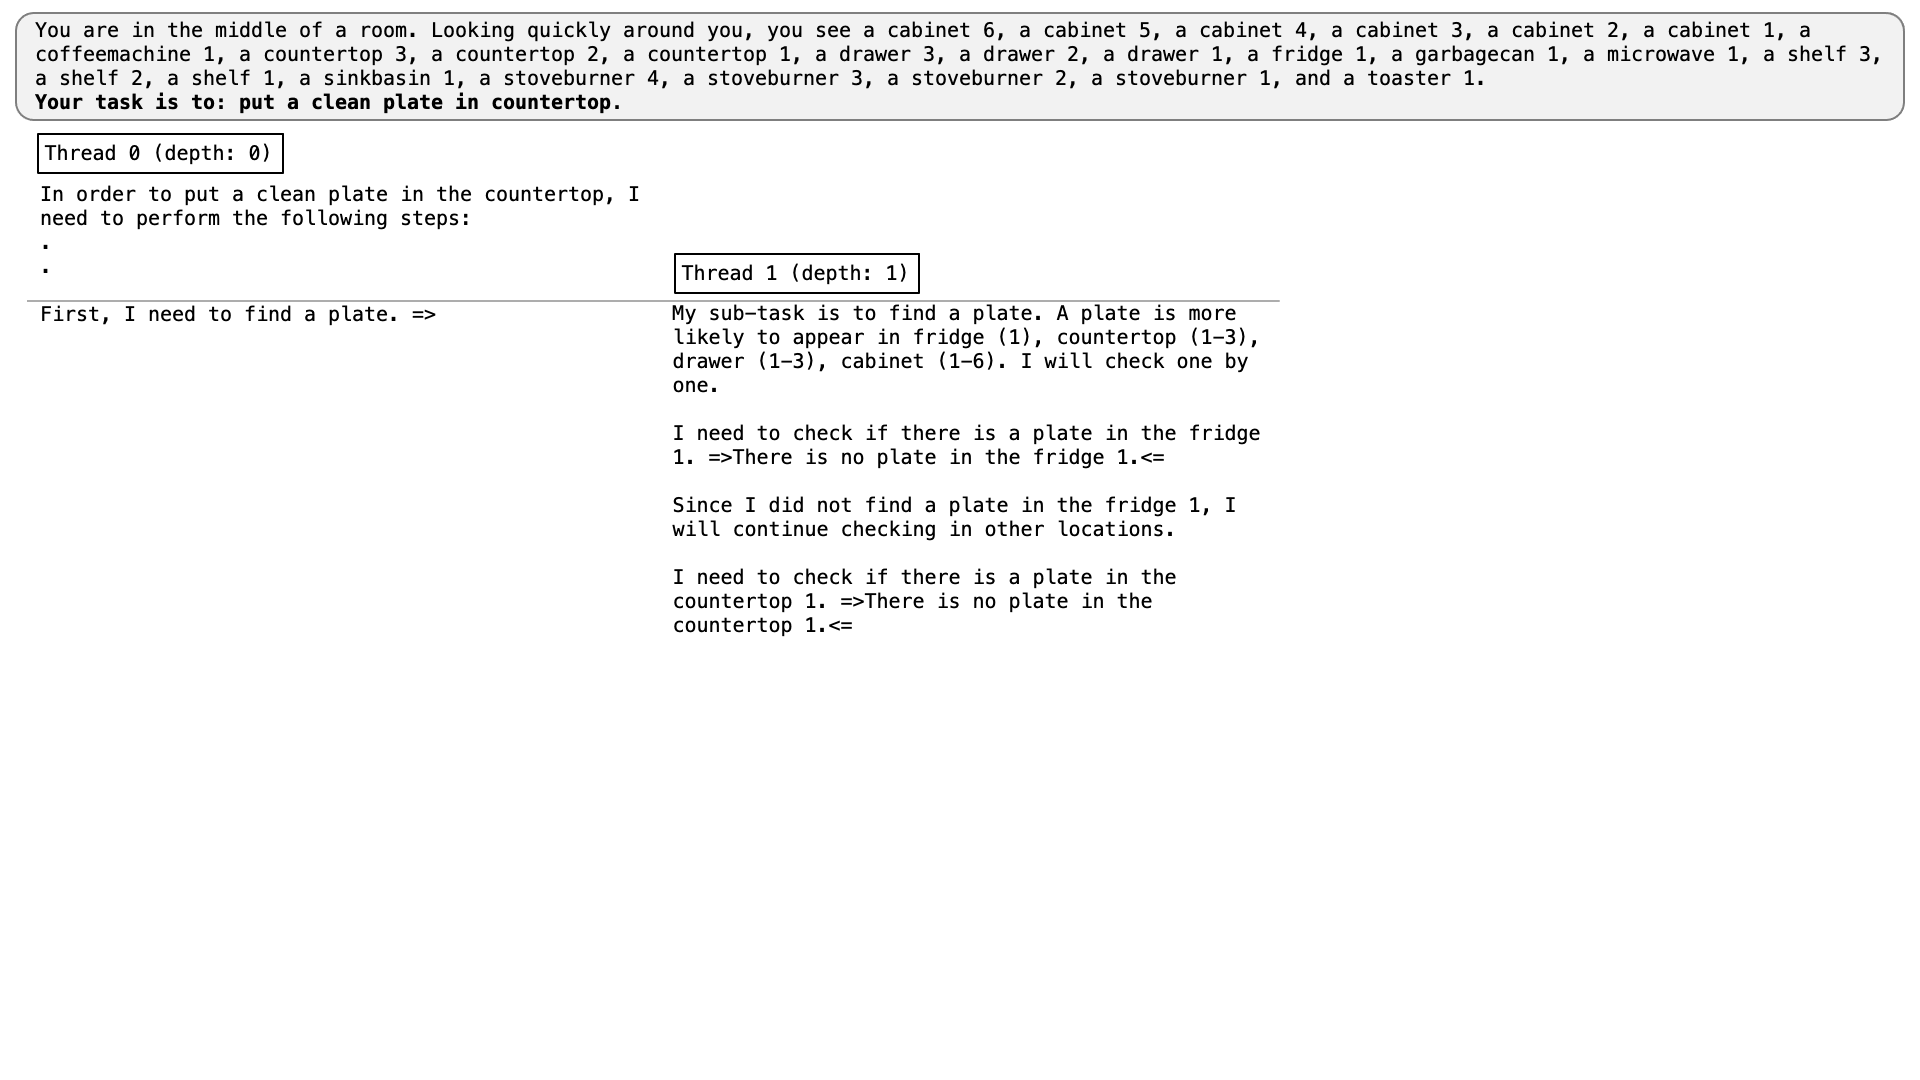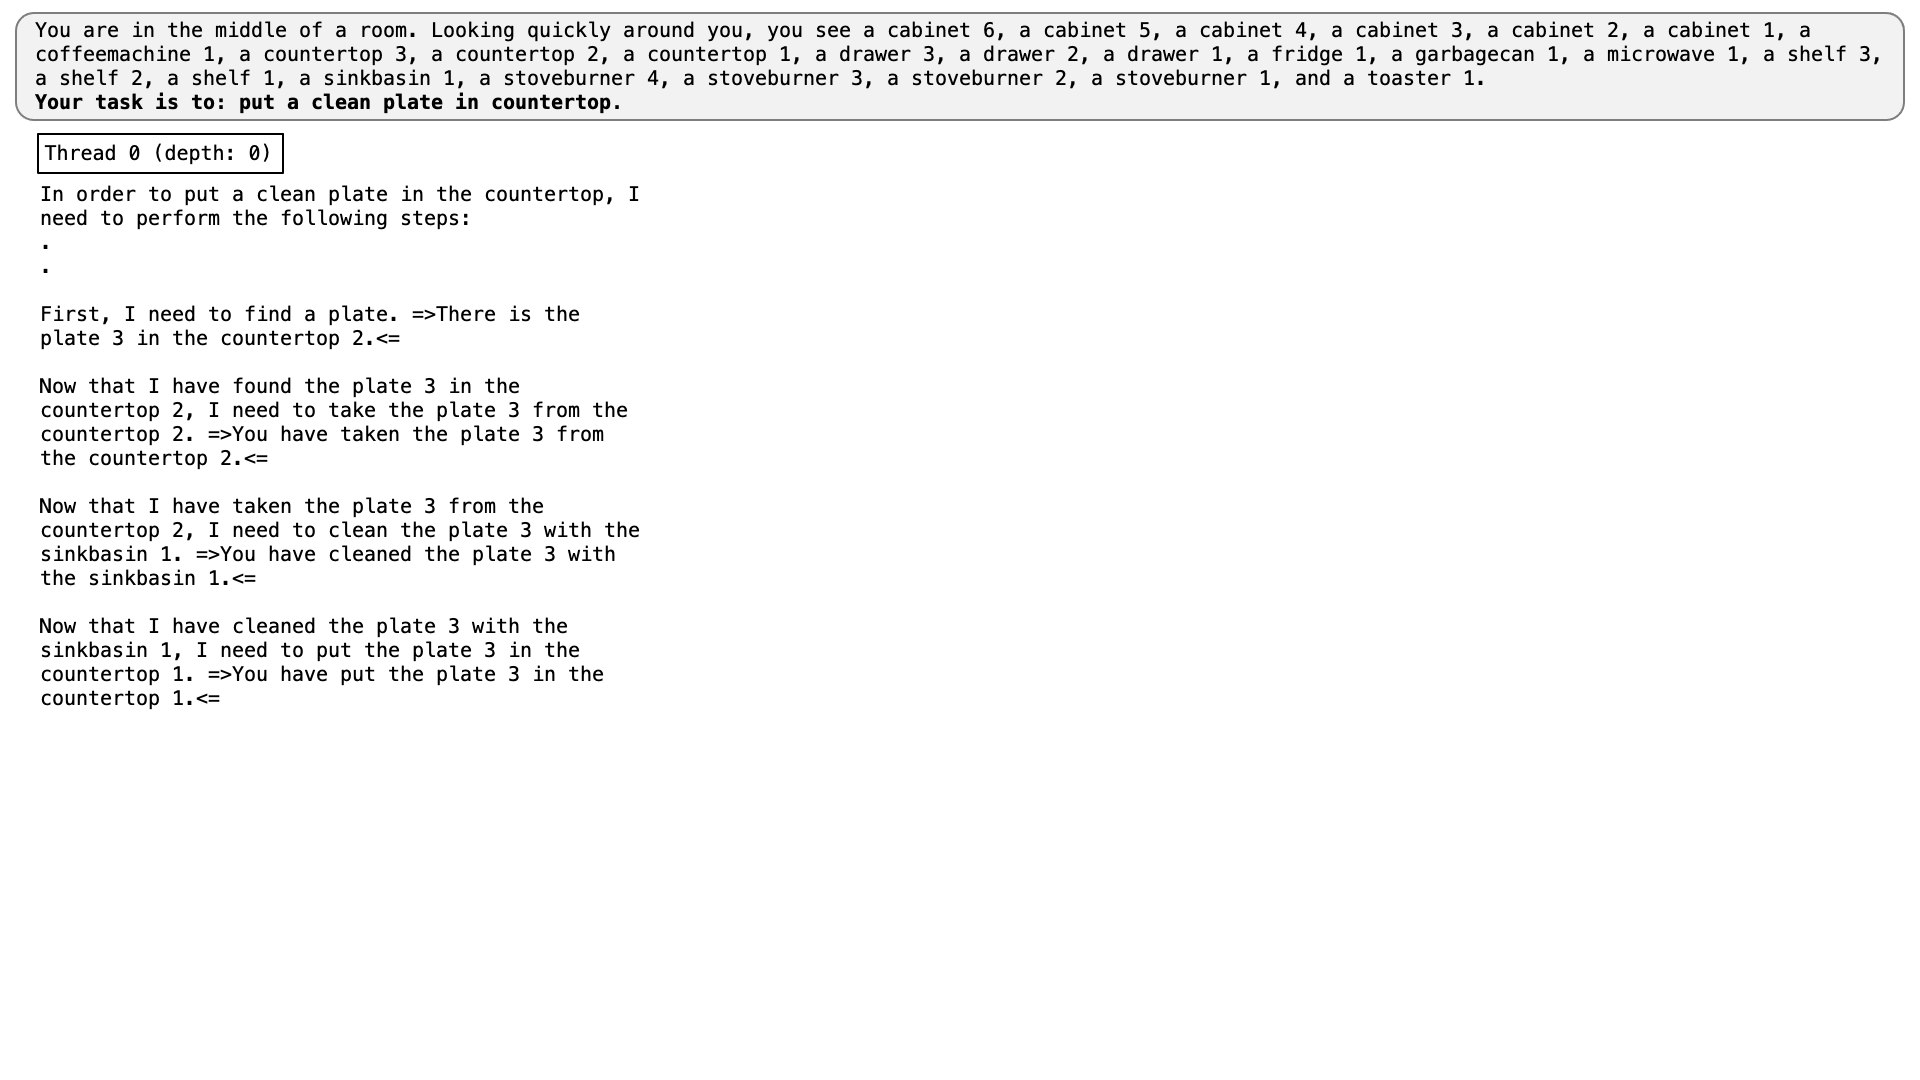
My early projects introduced recursive architectures for transformer decoding that improve the performance of LLMs and VLMs when interacting with external environments through text or video. This work led to first-author papers at NeurIPS 2025 (introducing ROVER) and NAACL 2025 (introducing THREAD).
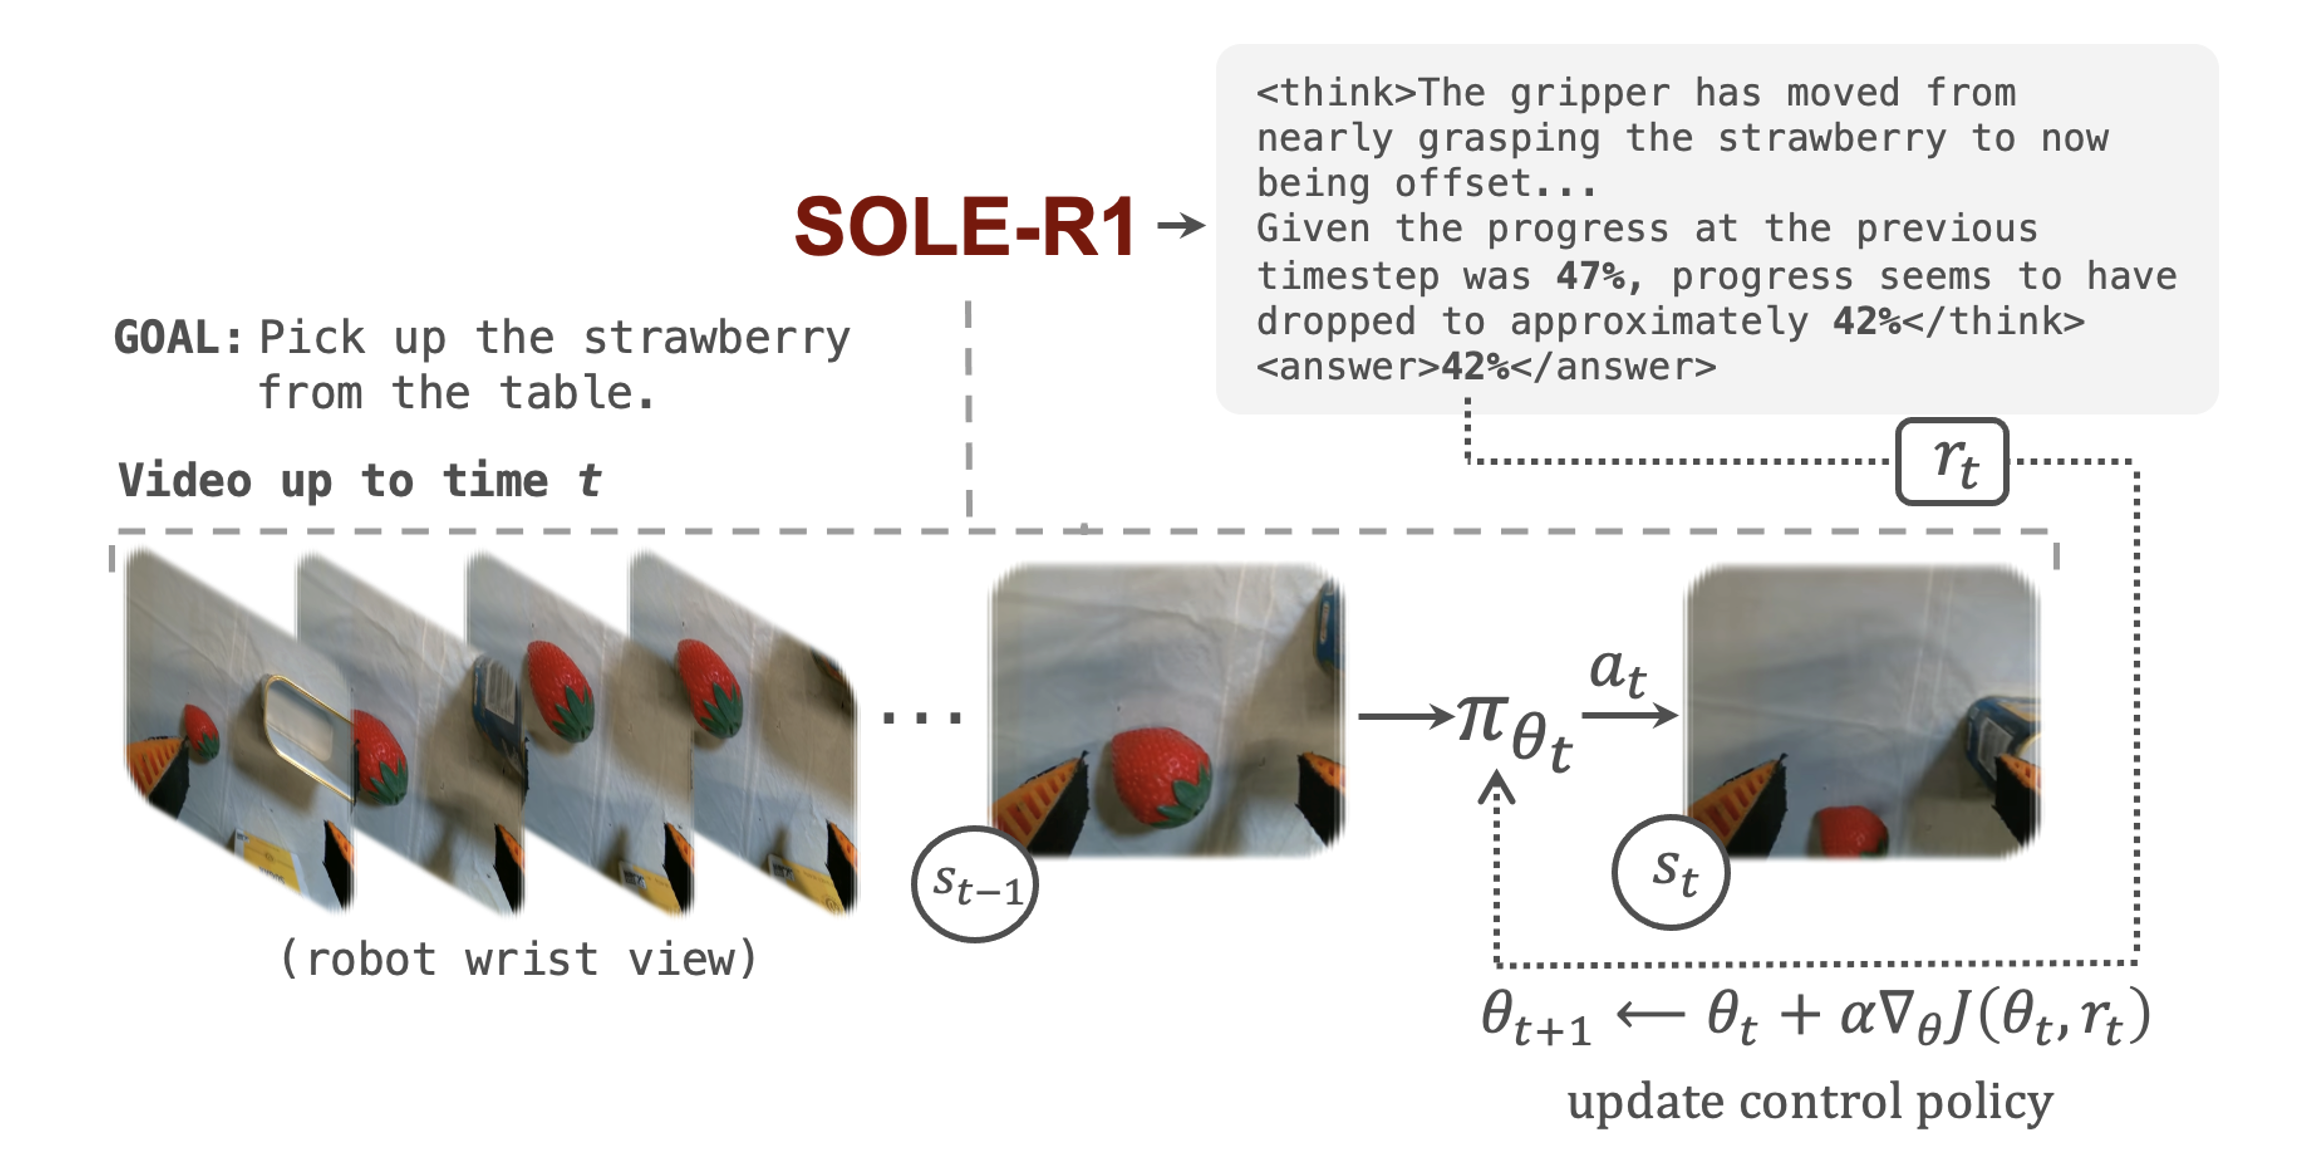
In my most recent work during my internship at the Boston Dynamics AI Institute (now RAI Institute), we introduce SOLE-R1: a new foundation reward model with video-language reasoning designed for guiding on-robot reinforcement learning. In our paper (which will be presented at NeurIPS 2026), we show SOLE-R1's zero-shot reward prediction can serve as the SOLE signal for learning over 20 unseen manipulation tasks through online RL: i.e., no demonstrations, no ground-truth rewards, randomly initialized policies, 0% starting success rate.
This work has led me to build Sublinear, the world's first API for foundation reward models for robots.
News
-
2026/10Went on RoboPapers to discuss our work with training general-purpose reward models for online RL, including SOLE-R1
-
2026/09SOLE-R1 is accepted at NeurIPS 2026!
-
2026/02
-
2025/12NeurIPS 2025 paper - ROVER: Recursive Reasoning Over Videos with VLMs for Embodied Tasks.
-
2025/05Started my summer internship at the Boston Dynamics AI Institute (now RAI Institute) with Ondrej Biza.
-
2025/04Talk: MIT Embodied Intelligence Seminar - "Recursive Reasoning with LLMs and VLMs"
-
2024/08NAACL 2025 paper - THREAD: Thinking Deeper with Recursive Spawning.
-
2023/09Started my PhD at MIT, Cambridge, MA.
Selected First-Author Papers
Talks/Interviews
-
SOLE-R1 and training general-purpose reward models for online RL
RoboPapers episode #111, October 9, 2026Recursive Reasoning with LLMs and VLMs
MIT Embodied Intelligence Seminar, April 24, 2025THREAD: Thinking Deeper with Recursive Spawning
NAACL 2025, April 2025