Physical intelligence · Robotics · Simulation

Research Notes

Essays and experimental notes on geometry, robot control, simulation, and models of the physical world.

2026

Essays & experiments

  • Geometry

    To Scale or Not to Scale

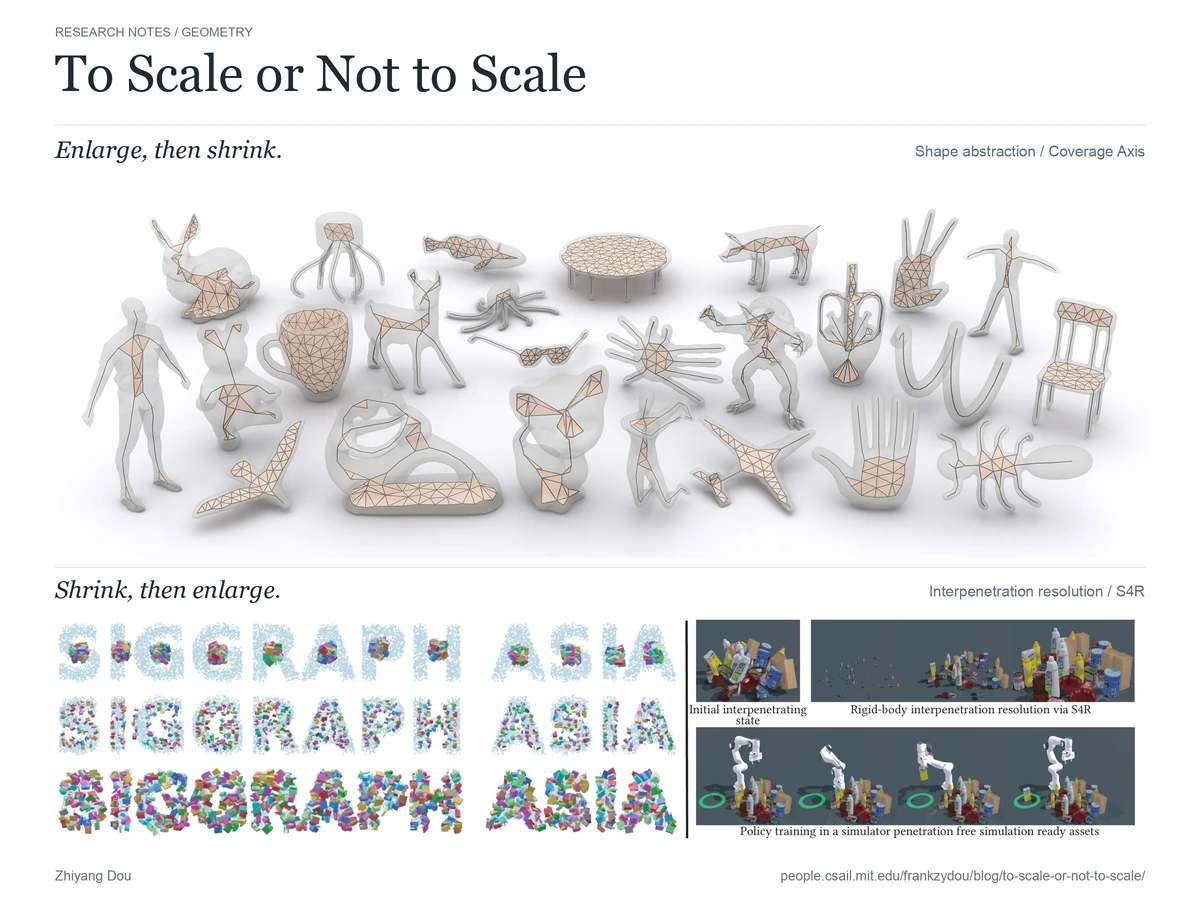
    Enlarge, then shrink: select a compact skeletal representation through surface coverage. Shrink, then enlarge: resolve interpenetration by creating clearance and adjusting poses.

    Shape analysis · Interpenetration resolution · Geometric optimization
    Cite this note BibTeX

    Dou, Z. (2026, September 20). To Scale or Not to Scale. Research Notes.

    @misc{dou2026toscale,
      author = {Dou, Zhiyang},
      title = {To Scale or Not to Scale},
      year = {2026},
      month = sep,
      howpublished = {Research Notes},
      url = {https://frank-zy-dou.github.io/blog/to-scale-or-not-to-scale/}
    }
  • Robot control

    Robotic hand self-righting with visual feedback

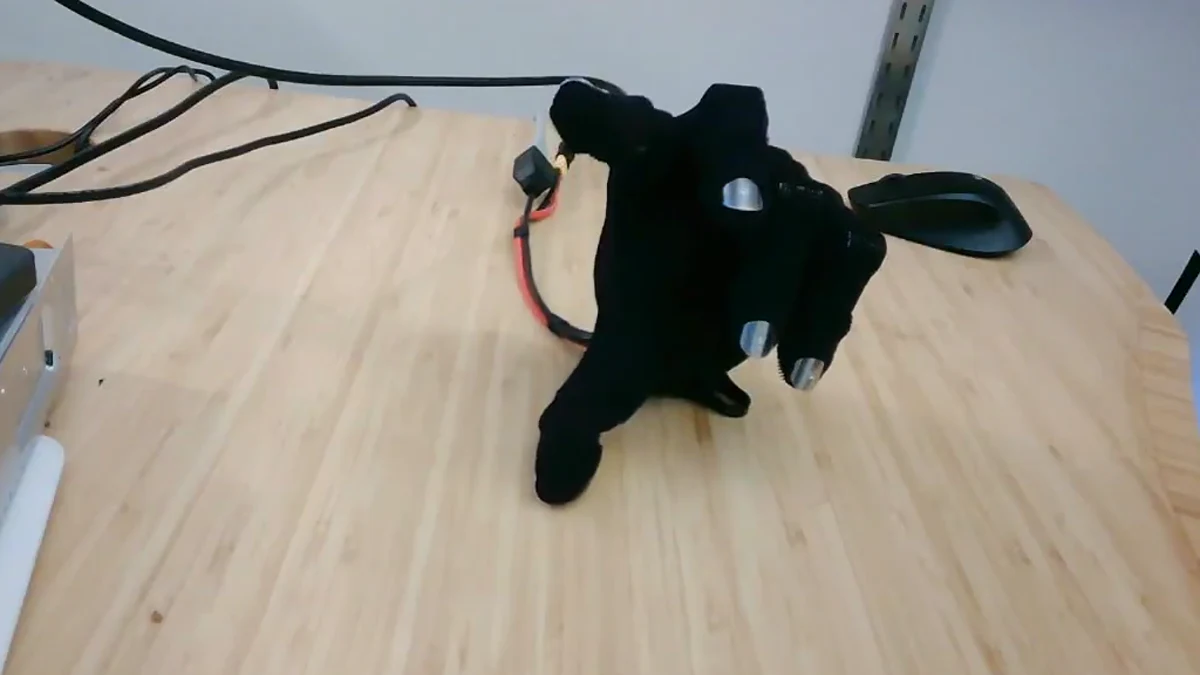
    I asked Astra to get a Wuji2 hand upright. It used its fingers to stand, then stayed there with its motors switched off. A closer look at the pose search and contact sequence.

    Dexterous hands · Simulation · Visual feedback
    Cite this note BibTeX

    Dou, Z. (2026, September 17). Robotic hand self-righting with visual feedback. Research Notes.

    @misc{dou2026handselfrighting,
      author = {Dou, Zhiyang},
      title = {Robotic hand self-righting with visual feedback},
      year = {2026},
      month = sep,
      howpublished = {Research Notes},
      url = {https://frank-zy-dou.github.io/blog/wuji2-hand-stands-up/}
    }
  • Robot manipulation

    Language-guided manipulation on a low-cost robot arm

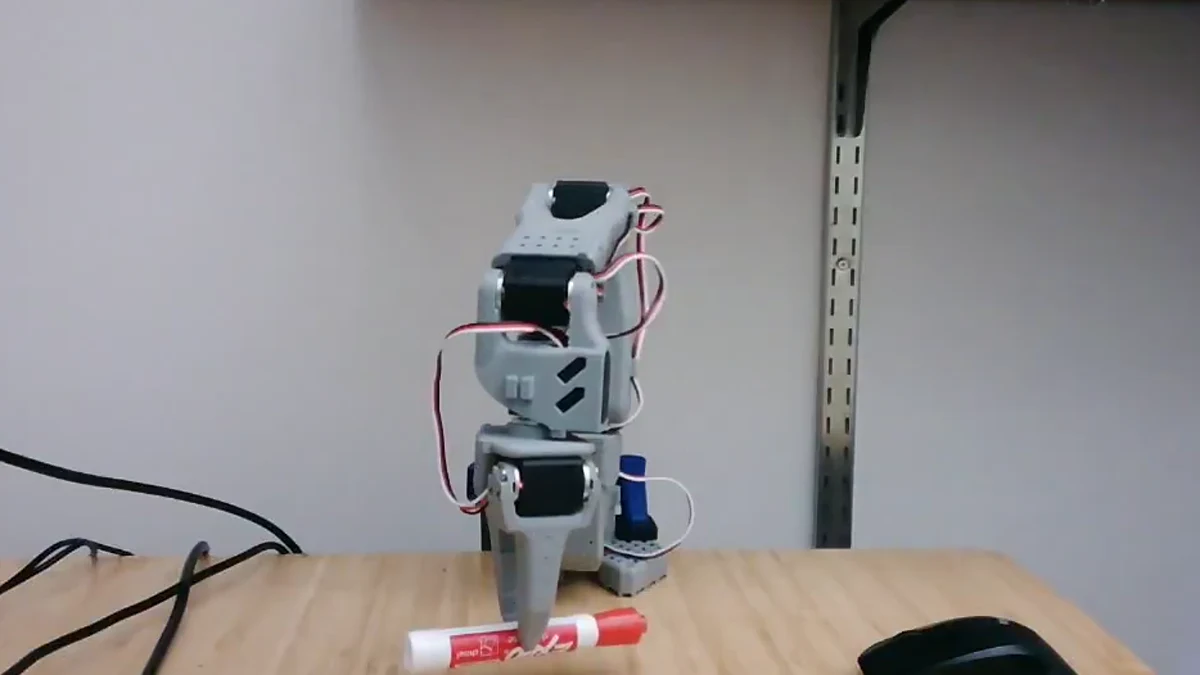
    One RGB camera, a LeRobot SO101, and 22 minutes to pick up a pen. What I observed about the control loop, and where I would look to make it faster.

    Language models · Manipulation · Real-world control
    Cite this note BibTeX

    Dou, Z. (2026, September 13). Language-guided manipulation on a low-cost robot arm. Research Notes.

    @misc{dou2026so101pickup,
      author = {Dou, Zhiyang},
      title = {Language-guided manipulation on a low-cost robot arm},
      year = {2026},
      month = sep,
      howpublished = {Research Notes},
      url = {https://frank-zy-dou.github.io/blog/so101-pen-pickup/}
    }
  • Scene reconstruction

    Articulated digital twins from monocular video

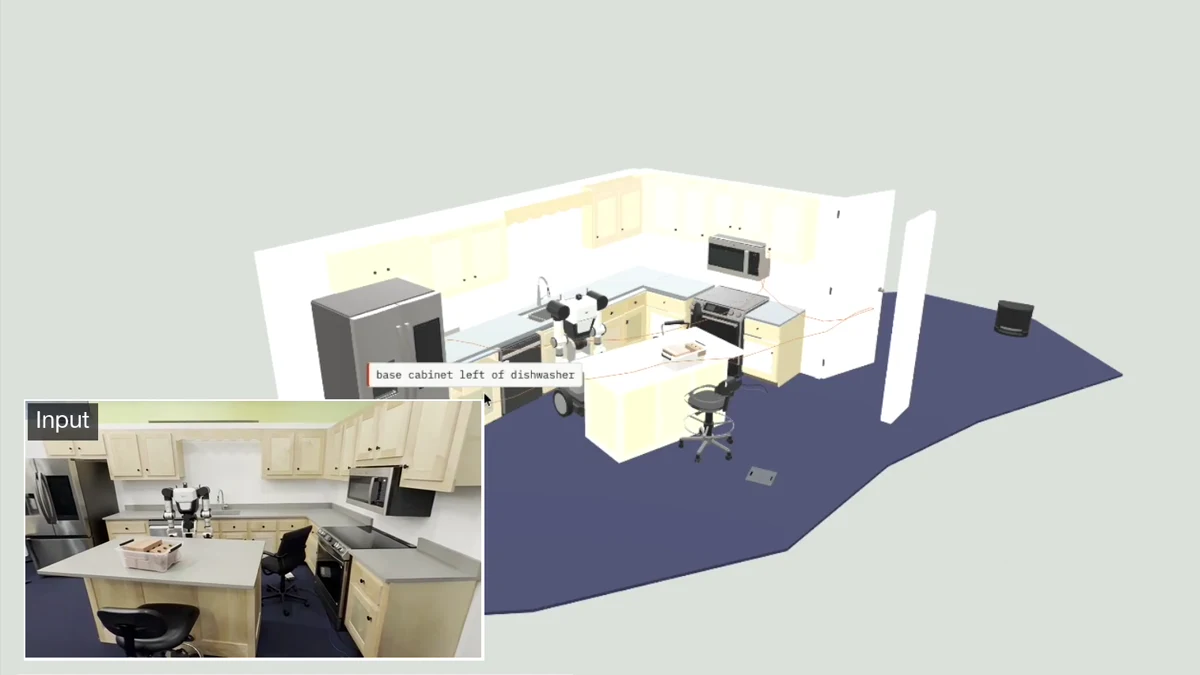
    I built a kitchen twin from a 20-second phone video, down to movable doors and drawers. Notes on visual checks and what still needs testing before robot use.

    Digital twins · 3D reconstruction · Articulated assets
    Cite this note BibTeX

    Dou, Z. (2026, September 11). Articulated digital twins from monocular video. Research Notes.

    @misc{dou2026kitchentwin,
      author = {Dou, Zhiyang},
      title = {Articulated digital twins from monocular video},
      year = {2026},
      month = sep,
      howpublished = {Research Notes},
      url = {https://frank-zy-dou.github.io/blog/kitchen-twin-from-video/}
    }